Skip to content
Jagmohan Meher

Tainan, Taiwan  ·  Robotics & AI

Jagmohan MeherRobotics and AI Engineer

Robotics and AI engineer in Taiwan. I build software that makes robots and factories smarter: multi-brand robot control, autonomous mobile manipulation, computer vision, and ROS 2 systems.

A small white robot with amber joints standing on a blueprint grid

R&D engineering
5+ yrs
of robots under one interface
5 brands
students taught robotics
5,000+
Young Investigator, ICBHI 2022
1st

01 / Projects

Robots I have built and shipped

Industrial arms, mobile manipulation, and perception. Real hardware, real factories.

[TODO: QROS: one interface for five robot brands media]

Industrial roboticsJun 2024 – May 2025

QROS: one interface for five robot brands

A single, intuitive control software for factory workers that drives Denso, Universal Robots, Kawasaki, Fanuc, and ABB arms from one screen.

  • C#
  • .NET
  • Motion planning
  • TCP calibration
  • 2D and 3D camera integration

[TODO: Autonomous mobile pick-and-place robot media]

Industrial roboticsJun 2024 – May 2025

Autonomous mobile pick-and-place robot

A Denso Cobotta Pro arm mounted on a MiR mobile robot that navigates a warehouse, finds objects with a depth camera, and picks and places them on its own.

  • ROS 2 Humble
  • Ubuntu 22.04
  • MiR AMR
  • Denso Cobotta Pro
  • RealSense L515

[TODO: host video file] Data collection: facial video recorded while cycling, from four angles

ResearchOct 2021 – Feb 2024

Measuring heart rate from video: does face alignment matter?

Master's thesis on remote photoplethysmography (rPPG): reading heart rate from a face on camera, and testing how much face alignment actually helps.

  • Python
  • Deep learning
  • Computer vision
  • rPPG (CHROM)
  • Face alignment (PRN, 3DDFA-V2)

[TODO: Visual servoing with a collaborative arm media]

Industrial robotics

Visual servoing with a collaborative arm

Camera-guided motion for a Denso Cobotta Pro: the arm follows what the camera sees, with a PD controller keeping the movement smooth.

  • ROS 2 Humble
  • Ubuntu 22.04
  • Denso Cobotta Pro
Honeywell IMU driver demo▶ YouTube

Industrial robotics

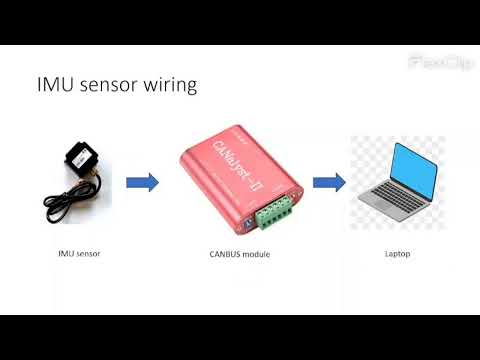
ROS 2 driver for a Honeywell IMU

A ROS 2 Humble driver for a Honeywell inertial measurement unit, speaking CAN bus, Ethernet, RS232, and USB.

  • ROS 2 Humble
  • Ubuntu 22.04
  • CAN bus

[TODO: host video file] Video analysis demo

Computer vision

Advanced computer vision video analysis

Three classic computer vision techniques implemented on video: background subtraction, optical flow, and perspective transformation.

  • Python
  • OpenCV

[TODO: Augmented reality on a chessboard media]

Computer vision

Augmented reality on a chessboard

Camera calibration and augmented reality: 3D characters rendered onto a real chessboard seen through the camera.

  • Python
  • OpenCV
  • Camera calibration

[TODO: Handwritten digit recognition media]

Computer vision

Handwritten digit recognition

A neural network that reads handwritten digits from pixel images and predicts the number.

  • Python
  • Deep learning

[TODO: Walking robots and a Bluetooth arm media]

Mechatronics

Walking robots and a Bluetooth arm

Hands-on mechatronics: a hexapod that crosses rocky terrain, a biped that mimics human gait, and a 3-DOF arm driven from a phone.

  • Mechanical design
  • Embedded control
  • Bluetooth

[TODO: Industrial sorting machine with a PLC media]

Mechatronics

Industrial sorting machine with a PLC

A PLC-controlled machine that detects objects and places each one in its correct location.

  • PLC
  • Sensors
  • Actuators

[TODO: Automatic parking system with IoT media]

IoT

Automatic parking system with IoT

A connected system that keeps count of vehicles in a parking area and reports it automatically.

  • IoT
  • Sensors
  • Microcontroller

02 / Experience

Where I have worked

From ed-tech robotics in Bangalore to research in Tainan to factory automation in New Taipei.

  1. [TODO: start month] – Present

    [TODO: current title]

    [TODO: current role] · Taiwan

    [TODO: one-line description at a publishable level, see F09]

  2. Jun 2024 – May 2025

    Software Engineer

    Quadrep Electronics Taiwan Ltd · New Taipei, Taiwan

    Developed software to automate assembly lines in factories using AI and machine learning.

    • Developed QROS (Quadrep Operating System), a tool to control and operate multiple robot brands from a single, intuitive user interface. Supported brands included Denso, Universal Robots, Kawasaki, Fanuc, and ABB.
    • Developed a smart pick-and-place application by mounting a Denso Cobotta Pro on a MiR autonomous mobile robot. It used a RealSense camera to perceive racks in an AI server room and performed accurate pick and place.
    • Developed a ROS 2 Humble driver for the Honeywell IMU sensor.
  3. Oct 2021 – Feb 2024

    Research Assistant

    Nordling Lab, National Cheng Kung University · Tainan, Taiwan

    Researched machine learning and deep neural networks for face alignment and remote photoplethysmography (rPPG), measuring heart rate from facial video, in Python.

    • First rank in the Young Investigator Competition at the International Conference on Biomedical and Health Informatics (ICBHI 2022), Concepcion, Chile, for the best research paper and presentation.
    • Collected, cleaned, and maintained experimental data including video and physiological signals. Trained other researchers in data collection and management.
    • Developed deep neural network models to calculate heart rate from facial video recordings.
    • Implemented lean strategies to improve how the lab ran, contributing to multiple grants, conference papers, and journal publications.
  4. Oct 2018 – Oct 2021

    Lead Robotics R&D Engineer

    Skyfi Labs · Bangalore, India

    Started as an R&D engineer building automation projects and mentoring students, then led the robotics R&D team and built the processes behind R&D, customer experience, sales, marketing, and inventory.

    • Developed industrial robots such as an automated colour-sorting machine, an industrial line-following and obstacle-avoiding robot, and industrial robotic arms.
    • Designed, maintained, and delivered hands-on training on building and programming robots for a range of tasks.
    • Built a community of more than 1000 young roboticists aged 5 to 15 who build robots and write code to tackle real-world problems.
    • Hired, trained, and supervised a team of more than 30 researchers and robotics engineers.

About

I'm a robotics engineer with over five years of R&D experience, currently based in Tainan, Taiwan. I work at the meeting point of hardware and AI: mechanical and electrical systems, Python and C#, ROS 2, and deep learning models that see and decide.

Most recently I built software to automate factory assembly lines: a single interface to drive five brands of industrial robots, and an autonomous pick-and-place robot that combines a mobile base, a collaborative arm, and a depth camera.

Before that I did research on computer vision for non-contact heart-rate measurement, and spent three years leading a robotics R&D team at an ed-tech company, where I taught robotics to thousands of students and mentored a community of young roboticists.

I was born in Odisha, India. My parents are teachers and my brother is an architect.

Education

Master of Science, Mechanical Engineering

National Cheng Kung University · Sep 2021 – Feb 2024

GPA 4.18

Bachelor of Technology, Electronics and Communication

Lovely Professional University · Aug 2014 – Jun 2018

CGPA 8.56/10

Languages

  • English · Advanced (TOEFL iBT 102/120)
  • Hindi · Native
  • Spanish · Intermediate
  • Chinese (Traditional) · Beginner

Off the clock

  • Calisthenics
  • Yoga
  • Bicycling
  • Reading

03 / Skills

Tools I work with

Robotics and automation

  • ROS 2
  • MoveIt 2
  • Gazebo
  • Robot programming
  • PLC
  • SCADA
  • Arduino
  • Raspberry Pi

AI and machine learning

  • PyTorch
  • TensorFlow
  • Keras
  • Scikit-learn
  • OpenCV
  • Deep learning

Programming

  • Python 3
  • C++
  • C#
  • MATLAB
  • Linux command line

Data

  • Analysis
  • Visualization
  • Prediction
  • Regression
  • Tableau

Electronics

  • Digital circuits
  • IC processing
  • Lithography
  • Verilog
  • VLSI

Leadership

  • Team leadership
  • Critical thinking
  • Written and spoken communication
  • Ownership

04 / Research

Publications and awards

  • A survey and classification of face alignment methods based on face model

    arXiv preprint, submitted to the International Journal of Computer Vision · 2023

    arXiv

  • Acquisition and synchronization of cardiography signals from a clinical patient monitor with facial video recordings

    International Conference on Biomedical and Health Informatics (ICBHI 2022), published in the IFMBE Proceedings · 2022

    Published versionPreprint

  • Evaluating the Impact of Face Alignment Techniques on Video-based Non-contact Heart Rate Measurement

    Master's thesis, National Cheng Kung University · 2024

    NCKU thesis library

  • 2022

    First rank, Young Investigator Competition

    International Conference on Biomedical and Health Informatics (ICBHI 2022)

    Top honour for the best research paper and presentation.

  • 2021

    NCKU International Distinguished Student Scholarship

    National Cheng Kung University

  • 2014

    LPU NEST Scholarship

    Lovely Professional University

05 / Teaching

Teaching and community

Robotics for students aged 5 to 62, in 12 countries.

  • 50+

    workshops delivered

  • 5,000+

    students trained

  • 1,000+

    young roboticists in the community

  • 12

    countries

  • Robotics training

    Delivered more than 50 workshops, trained more than 5000 students aged 5 to 62, and built a community of more than 1000 young roboticists across 12 countries.

  • Skyfi Labs Innovation Challenge

    Mentored over 300 students through the challenge, culminating in a showcase of the most outstanding projects.

  • Girls Innovate for Tomorrow (GIFT)

    Ran a robotics development program for 500 underprivileged young girls. 75 of them showcased their projects to officials from Intel and NASSCOM.

  • Glider workshop, IIT Delhi

    Trained 1200 aspiring engineers in aerodynamics principles with hands-on glider building.

  • 7-day robotics workshop, Andaman and Nicobar Islands

    Delivered a week-long robotics workshop at Dr. B.R. Ambedkar University in the Andaman and Nicobar Islands, India.

  • OpenCV workshop

    A talk on the fundamentals of computer vision with hands-on coding, building a colour-based object detector.

▶ Skyfi Labs Innovation Challenge▶ OpenCV workshop, part 1▶ OpenCV workshop, part 2

06 / Contact

Let's build something that moves.

Open to robotics, physical AI, and automation work. Reach me by email or on LinkedIn.